Prof. Ravi Prakash

Ravi Prakash

Assistant Professor, Department of Cyber-Physical Systems, Indian Institute of Science
Head, Human-interactive Robotics (HiRo) Lab
I am an Assistant Professor in the Department of Cyber-Physical Systems at the Indian Institute of Science (IISc), where I lead the Human-interactive Robotics (HiRo) Lab. My research develops provably safe, sample-efficient learning and control for robots operating in uncertain, contact-rich environments, spanning imitation and reinforcement learning, compliant and optimal control, and the grounding of foundation models for robot manipulation and physical human–robot interaction, with applications in assistive robotics and intelligent manufacturing.

I earned my Ph.D. in Control and Automation from IIT Kanpur, advised by Prof. Laxmidhar Behera, and then held an ERC-funded postdoctoral position with Prof. Jens Kober in the Learning and Autonomous Control group at TU Delft. I am a 2022 DAAD AInet Fellow and a co-author of the survey Interactive Imitation Learning in Robotics (Now Publishers, 2022).

Publications

Book (1) Journal Publications (10) Conference Publications (22) Workshop Papers (9)

Book
Journal Publications
DiffusionPack: Offline Bin Packing with Custom Human Preferences
RA-L'26
DiffusionPack: Offline Bin Packing with Custom Human Preferences
A Maurya, S Vats, G Balachandran, R Prakash
Preliminary version appeared at NeurIPS 2025 Workshop: Bridging Language, Agent, and World Models for Robotics
V-OCBF: Learning Safety Filters from Offline Data via Value-Guided Offline Control Barrier Functions
TMLR'26
V-OCBF: Learning Safety Filters from Offline Data via Value-Guided Offline Control Barrier Functions
Mumuksh Tayal*, Manan Tayal*, A Singh, S Kolathaya, R Prakash
* Equal contribution
Preliminary version appeared at AAAI 2026 Workshop on Deployable AI (DAI) (Oral)
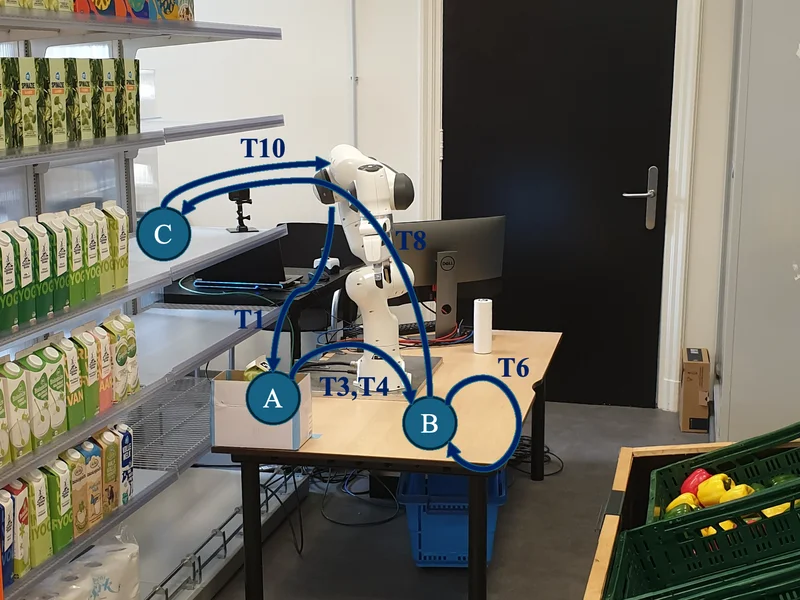
Sequentially Teaching Sequential Tasks (ST)2: Teaching Robots Long-Horizon Manipulation Skills
RA-M'26
Sequentially Teaching Sequential Tasks (ST)2: Teaching Robots Long-Horizon Manipulation Skills
OVITA: Open-Vocabulary Interpretable Trajectory Adaptations
RA-L'25
OVITA: Open-Vocabulary Interpretable Trajectory Adaptations
A Maurya, T Ghosh, A Nguyen, R Prakash
Preliminary version appeared at CoRL 2024 Workshop on Language and Robot Learning (LangRob)
Generalizable motion policies through keypoint parameterization and transportation maps
T-RO'25
Generalizable motion policies through keypoint parameterization and transportation maps
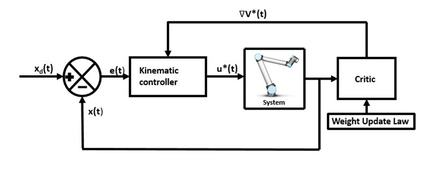
Adaptive Critic Optimal Control of an Uncertain Robot Manipulator With Applications
T-CST'24
Adaptive Critic Optimal Control of an Uncertain Robot Manipulator With Applications
Neural Optimal Control for Constrained Visual Servoing via Learning from Demonstration
T-ASE'23
Neural Optimal Control for Constrained Visual Servoing via Learning from Demonstration
R Prakash, L Behera
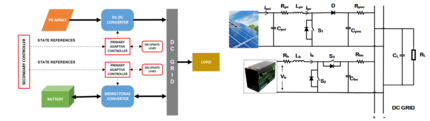
Model Free Adaptive Neural Controller for Standalone Photovoltaic Distributed Generation Systems With Disturbances
T-STE'22
Model Free Adaptive Neural Controller for Standalone Photovoltaic Distributed Generation Systems With Disturbances
Dual-loop Optimal Control of a Robot Manipulator and its Application in Warehouse Automation
T-ASE'22
Dual-loop Optimal Control of a Robot Manipulator and its Application in Warehouse Automation
Dynamic Trajectory Generation and a Robust Controller to Intercept a Moving Ball in a Game Setting
T-CST'20
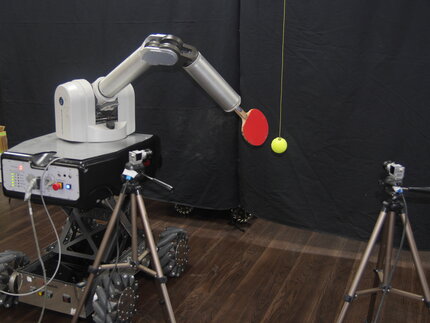
Dynamic Trajectory Generation and a Robust Controller to Intercept a Moving Ball in a Game Setting

Conference Publications
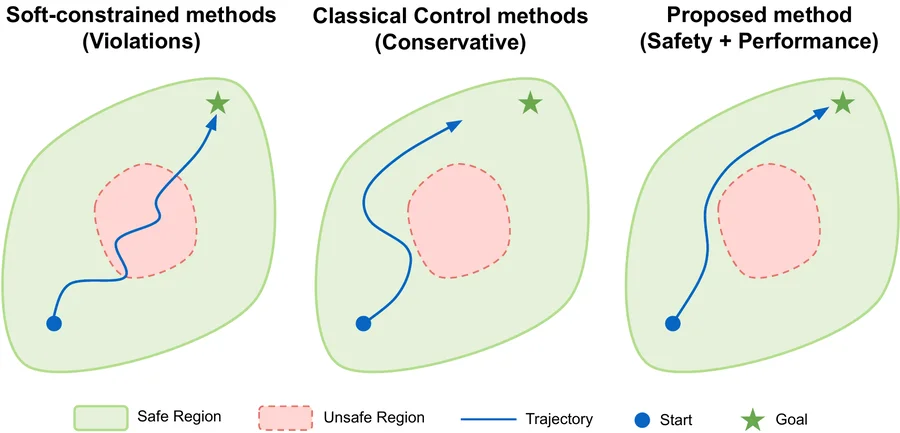
Bridging Safety and Performance in Autonomous Systems using Offline Reinforcement Learning
NeurIPS'26
Bridging Safety and Performance in Autonomous Systems using Offline Reinforcement Learning
Mumuksh Tayal*, Manan Tayal*, R Prakash
* Equal contribution
Preliminary version appeared at ICML 2026 Workshop: Agents in the Wild (AIWILD)
Beyond Visual Grasping: Benchmarking Complex Grasping from Detection to Execution
IROS'26
Beyond Visual Grasping: Benchmarking Complex Grasping from Detection to Execution
H Zhang, K Nguyen, C Munasinghe, B Hela, T Li, Z Luo, H Nguyen, HW van de Venn, Y Zheng, R Prakash, TD Ta, A Nguyen, B Huang
Gripper-aware Vision Language Action Models
ECCV'26
Gripper-aware Vision Language Action Models
H Zhang, Z Luo, T Li, K Nguyen, B Hela, S Kumar, ND Tran, F Dai, C Munasinghe, J Peña Queralta, G Toffetti, K Vo, N Le, R Prakash, Q Vuong, TD Ta, L Hu, A Nguyen, B Huang
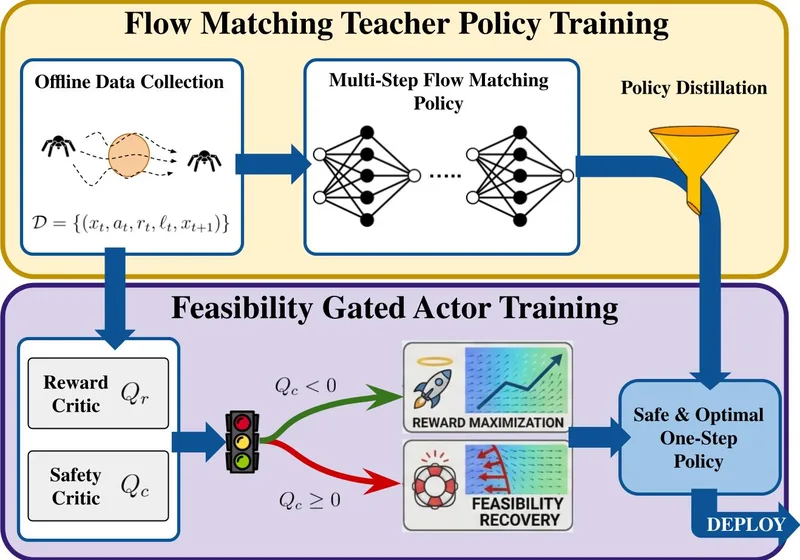
Safe Flow Q-Learning: Offline Safe Reinforcement Learning with Reachability-Based Flow Policies
RLC'26
Safe Flow Q-Learning: Offline Safe Reinforcement Learning with Reachability-Based Flow Policies
Mumuksh Tayal*, Manan Tayal*, R Prakash
* Equal contribution
Preliminary version appeared at ICML 2026 Workshop: Agents in the Wild (AIWILD)
AffordMatcher: Affordance Learning in 3D Scenes from Visual Signifiers
CVPR'26
AffordMatcher: Affordance Learning in 3D Scenes from Visual Signifiers
N Vu, T Do, K Nguyen, B Huang, N Le, BX Nguyen, E Tjiputra, QD Tran, R Prakash, T-C Chiu, A Nguyen
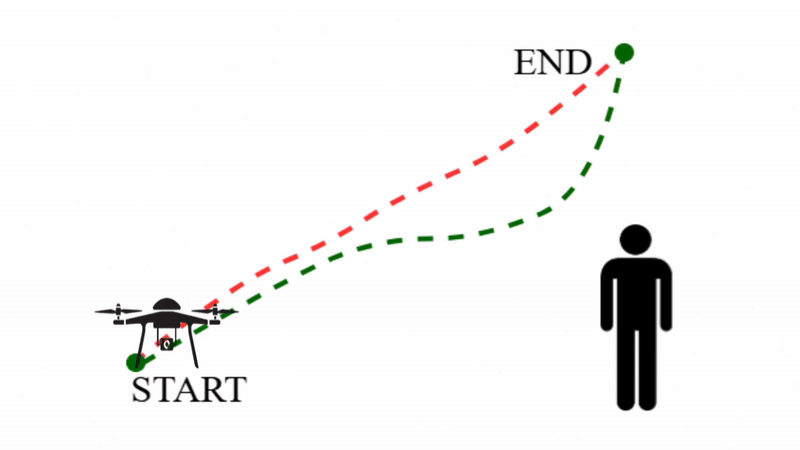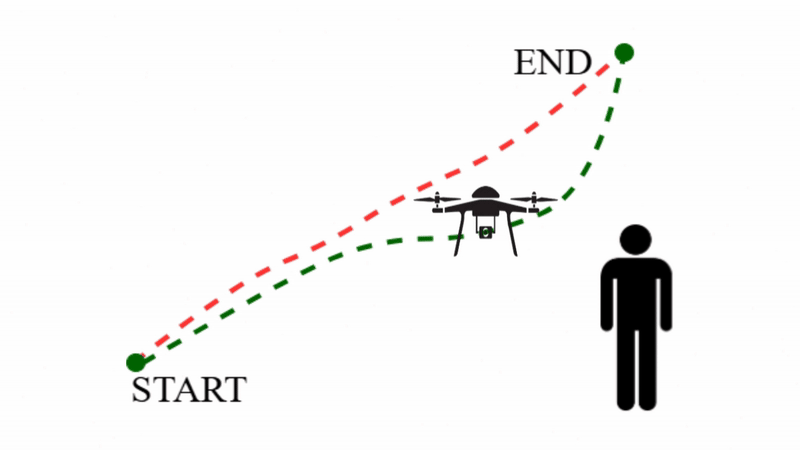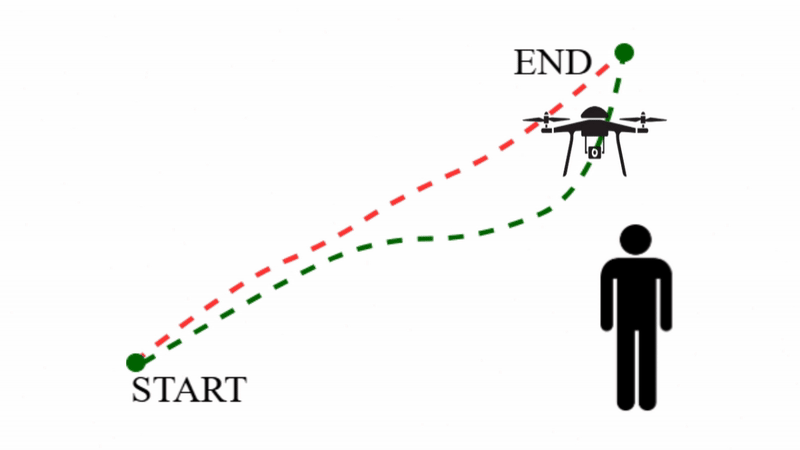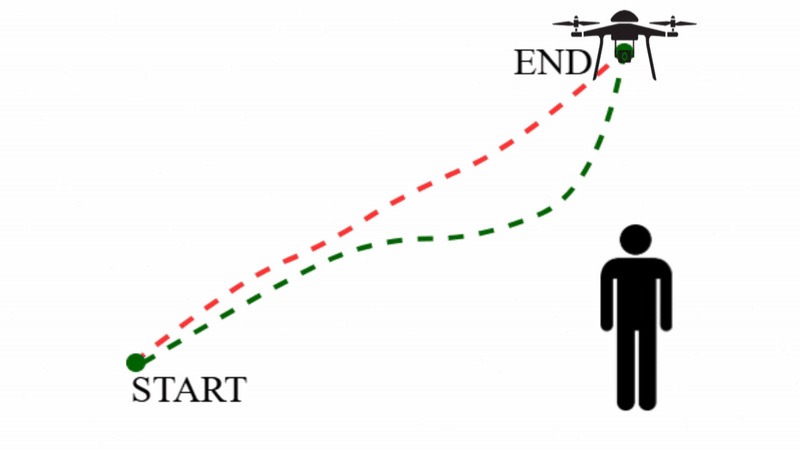
SafeDMPs: Integrating Formal Safety with DMPs for Adaptive HRI
ICRA'26
SafeDMPs: Integrating Formal Safety with DMPs for Adaptive HRI
P Tiwari, S Nath, R Prakash
Preliminary version appeared at CoRL 2025 2nd Workshop: Safe and Robust Robot Learning for Operation in the Real World
Beyond the Teacher: Leveraging Mixed-Skill Demonstrations for Robust Imitation Learning
ICRA'26
Beyond the Teacher: Leveraging Mixed-Skill Demonstrations for Robust Imitation Learning
S Saharsh*, S Sonkar*, P Jagtap, R Prakash
* Equal contribution
Preliminary version appeared at CoRL 2025 Workshop: Making Sense of Data in Robotics: Composition, Quality, and Data-centric Approaches
Safe and Optimal Variable Impedance Control via Certified Reinforcement Learning
ICRA'26
Safe and Optimal Variable Impedance Control via Certified Reinforcement Learning
S Kumar, R Prakash
Impedance Primitive-Augmented Hierarchical Reinforcement Learning for Sequential Tasks
ICRA'25
Impedance Primitive-Augmented Hierarchical Reinforcement Learning for Sequential Tasks
AB Tahmaz, R Prakash, J Kober
Closed Form HJB Solution for Path Planning of a Robot Manipulator with Warehousing Applications
CASE'22
Closed Form HJB Solution for Path Planning of a Robot Manipulator with Warehousing Applications
R Prakash, JK Mohanta, L Behera
IEEE International Conference on Automation Science and Engineering (CASE), Mexico City, 2022
End-To-End Real-Time Visual Perception Framework for Construction Automation
SMC'21
End-To-End Real-Time Visual Perception Framework for Construction Automation
M Vohra, A Kumar, R Prakash, L Behera
IEEE International Conference on Systems, Man, and Cybernetics (SMC), Melbourne, 2021
Edge and Corner Detection in Unorganized Point Clouds for Robotic Pick and Place Applications
ICINCO'21
Edge and Corner Detection in Unorganized Point Clouds for Robotic Pick and Place Applications
M Vohra, R Prakash, L Behera
Adaptive Backstepping Neural Tracking Control of an Uncertain Robot Manipulator with Dynamic Disturbances
SSCI'20
Adaptive Backstepping Neural Tracking Control of an Uncertain Robot Manipulator with Dynamic Disturbances
R Prakash, KV Gupta, L Behera
IEEE Symposium Series on Computational Intelligence (SSCI), Canberra, 2020
Towards Deep Learning Assisted Autonomous UAVs for Manipulation Tasks in GPS-Denied Environments
IROS'20
Towards Deep Learning Assisted Autonomous UAVs for Manipulation Tasks in GPS-Denied Environments
A Kumar, M Vohra, R Prakash, L Behera
IEEE/RSJ International Conference on Intelligent Robots and Systems (IROS), Las Vegas, 2020
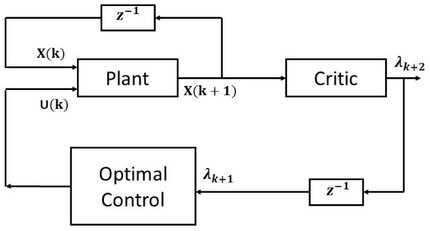
Discrete-Time Lyapunov based Kinematic Control of Robot Manipulator using Actor-Critic Framework
IJCNN'20
Discrete-Time Lyapunov based Kinematic Control of Robot Manipulator using Actor-Critic Framework
International Joint Conference on Neural Networks (IJCNN), Glasgow, 2020
Combined Online and Offline Inverse Dynamics Learning for a Robot Manipulator
IJCNN'20
Combined Online and Offline Inverse Dynamics Learning for a Robot Manipulator
International Joint Conference on Neural Networks (IJCNN), Glasgow, 2020
Learning Optimal Parameterized Policy for High Level Strategies in a Game Setting
RO-MAN'19
Learning Optimal Parameterized Policy for High Level Strategies in a Game Setting
R Prakash, M Vohra, L Behera
IEEE International Conference on Robot and Human Interactive Communication (RO-MAN), New Delhi, 2019
Real-time Grasp Pose Estimation for Novel Objects in Densely Cluttered Environment
RO-MAN'19
Real-time Grasp Pose Estimation for Novel Objects in Densely Cluttered Environment
M Vohra, R Prakash, L Behera
IEEE International Conference on Robot and Human Interactive Communication (RO-MAN), New Delhi, 2019
Adaptive Critic Based Optimal Kinematic Control for a Robot Manipulator
ICRA'19
Adaptive Critic Based Optimal Kinematic Control for a Robot Manipulator
A Menon, R Prakash, L Behera
IEEE International Conference on Robotics and Automation (ICRA), Montreal, 2019
Reward based Single Network Adaptive Critic for Optimal Kinematic Control of a Redundant Robot Manipulator
SSCI'18
Reward based Single Network Adaptive Critic for Optimal Kinematic Control of a Redundant Robot Manipulator
J Jose, R Prakash, L Behera
IEEE Symposium Series on Computational Intelligence (SSCI), Bangalore, 2018
Learning Object Manipulation from Demonstration through Vision for the 7-DOF Barrett WAM
CMI'16
Learning Object Manipulation from Demonstration through Vision for the 7-DOF Barrett WAM
N Das, R Prakash, L Behera
IEEE International Conference on Control, Measurement and Instrumentation (CMI), Kolkata, 2016
Preview coming soon
IFAC'14
Design of a Three Phase Squirrel Cage Induction Motor for Electric Propulsion System
R Prakash, MJ Akhtar, RK Behera, SK Parida
IFAC Proceedings Volumes, vol. 47, no. 1, pp. 801-806, 2014

Workshop Papers

Preview coming soon
CoRLW'26
Corrections Are Evidence, Not Targets: Operator-Aware Inversion for Adapting Frozen Generative Robot Policies
R Jadhav, S Bobade, S Viswanathan, SK Vidyarthi, L Nageswar, R Prakash
Preview coming soon
RSSW'26
Where Reasoning Does Not Matter: Isolating Chain-of-Thought in a Modular, Agentic VLM Manipulation Pipeline
B Hela, R Prakash
Preview coming soon
ICRAW'26
Latent Dynamics Modulation Guidance for Semantic Obstacle Avoidance in Diffusion Policies
S Alavala, V Buereddy, R Prakash
Preview coming soon
ICRAW'26
The Topological Cage: A Search-Less Geometric Handshake for Medial Axis Injection
SP Goswami, R Prakash
Preview coming soon
CVPRW'26
GenieMotion: Learning Object-Centric 4D Motion Representations from a Single Image via Generative Demonstrations
M Halder, R Prakash
Preview coming soon
ICRAW'26
State-Corrected Predictive Preference Learning for Multimodal Robot Navigation on Uneven Terrain
R Jadhav, AK Singh, S Ganguly, R Prakash, V Kumar
RISE: Robust Imitation through Stochastic Encodings
IROSW'25
RISE: Robust Imitation through Stochastic Encodings
Mumuksh Tayal, Manan Tayal, R Prakash
PACER: Progress-Aligned Curation for Error-Resilient Imitation Learning
CoRLW'25
PACER: Progress-Aligned Curation for Error-Resilient Imitation Learning
S Kumar, R Prakash
3rd Workshop on Human-Interactive Robot Learning (HIRL)
HRI'24
3rd Workshop on Human-Interactive Robot Learning (HIRL)
M Racca, R Mirsky, E Senft, X Xiao, I Idrees, A Kshirsagar, R Prakash

Recognition & Service

  • 2027
    Associate Editor, IEEE International Conference on Robotics and Automation (ICRA)
  • 2024
    Co-organizer, 3rd Workshop on Human-Interactive Robot Learning (HIRL), ACM/IEEE HRI
  • 2023
    Associate Editor, IEEE/RSJ International Conference on Intelligent Robots and Systems (IROS)
  • 2022
    DAAD AInet Fellow (AI and Robotics), with a funded research visit to the German Aerospace Center (DLR), Munich
  • 2017
    3rd place worldwide in Picking, Amazon Robotics Challenge, Nagoya (Team IITK-TCS)

Teaching at IISc

  • August term
  • January term
    CP 321 Imitation Learning for Robotics
  • January term
    AE 372 Applied Optimal Control and State Estimation

Selected Talks

  • 2026
    Invited talk, "Manifold-Constrained Learning and Spatio-Temporal Safety for Provably Stable Robot Manipulation", RSS 2026 Workshop: From Imitation to Certification, Sydney
  • 2025
    Expert lecture, Workshop on Advanced Guidance, Control and State Estimation, IISc (with DRDO and IEEE CSS)
  • 2025
    "Adaptive and Reactive Learning and Control for Robots", FDP on Cyber-Physical Systems & Control
  • 2024
    "Robots for the Future", Distinguished Lecture, IEEE Day, IEEE RAS India
  • 2024
    "Generalization of Task-Parameterized Interactive Imitation Learning", EECS Symposium, IISc

Robotics Challenges
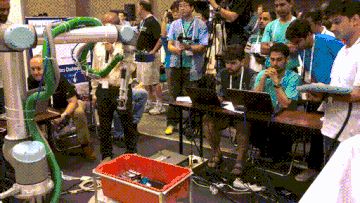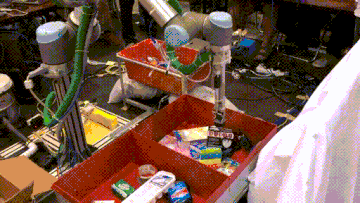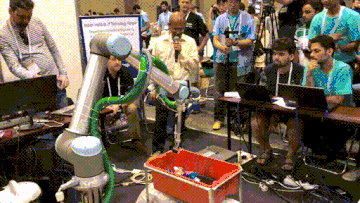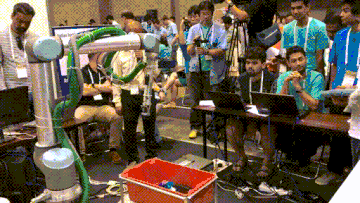
Amazon Robotics Challenge 2017, Nagoya, Japan
ARC'17
Amazon Robotics Challenge 2017, Nagoya, Japan
Team IITK-TCS (lead: Prof. Laxmidhar Behera). 3rd place in Picking and 5th in the Combined Finals among 40 international teams. Responsible for robot motion control: Cartesian movement primitives for approach, grasp, lift and retreat with point-cloud-based collision avoidance.
Amazon Picking Challenge 2016, Leipzig, Germany
APC'16
Amazon Picking Challenge 2016, Leipzig, Germany
Team IITK-TCS. 5th place in Stowing among 40 international teams. Responsible for motion control of the mobile manipulator.
Mohamed Bin Zayed International Robotics Challenge 2020, Abu Dhabi
MBZIRC'20
Mohamed Bin Zayed International Robotics Challenge 2020, Abu Dhabi
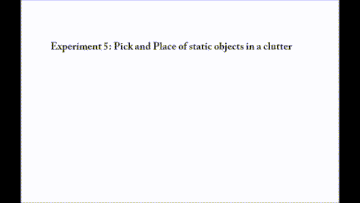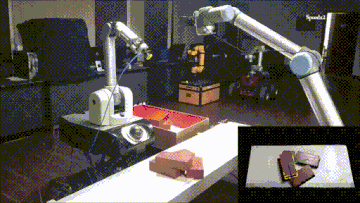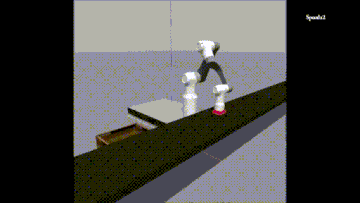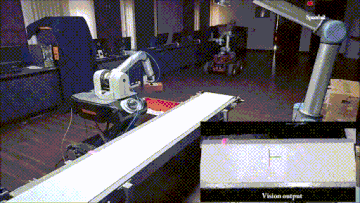
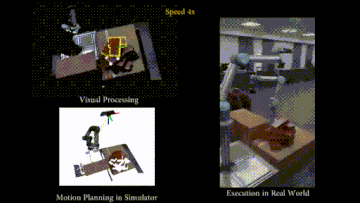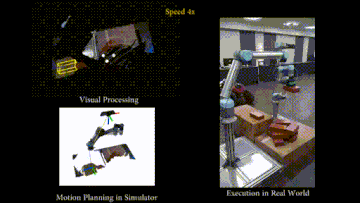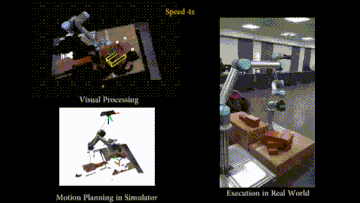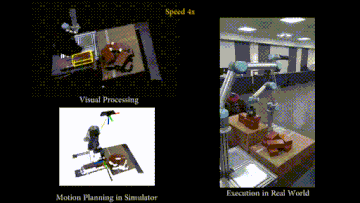
Team IIT Kanpur. UAVs and a UGV autonomously locating, picking, transporting and assembling bricks into predefined structures outdoors. Designed learning-from-demonstration motion planning and control for the UR5 mobile manipulator, and integrated the system in ROS.
IROS 2020 Open Cloud Robot Table Organization Challenge
OCRTOC'20
IROS 2020 Open Cloud Robot Table Organization Challenge
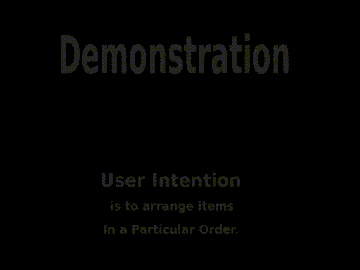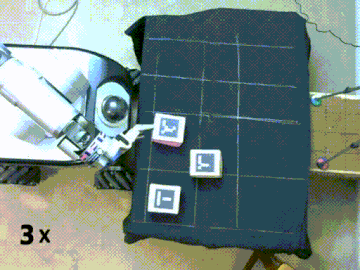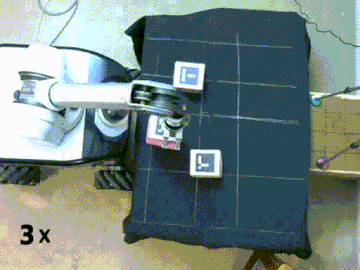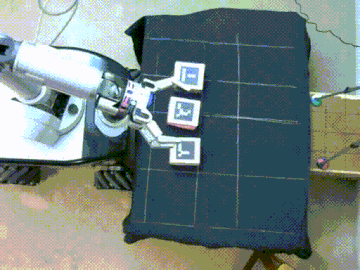
Team ISCon_IITK. Table organization with a cloud-based robot. Responsible for motion control using Dynamic Movement Primitives.