Publications
2026
NeurIPS'26
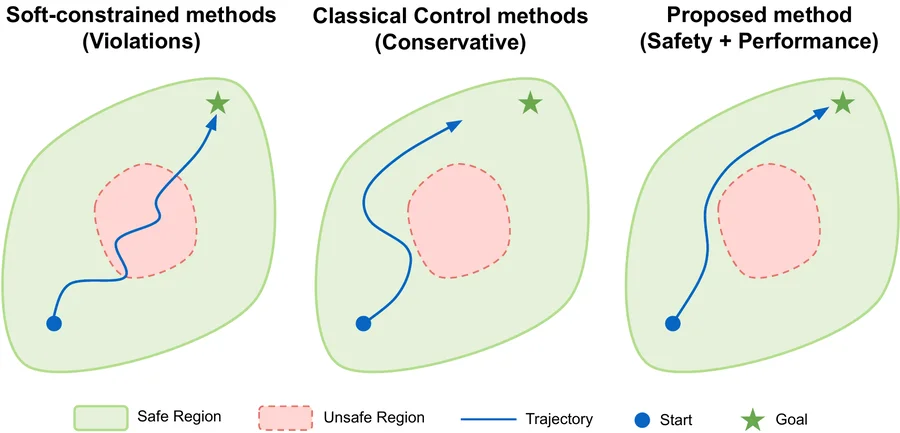
Bridging Safety and Performance in Autonomous Systems using Offline Reinforcement Learning
* Equal contribution
40th Annual Conference on Neural Information Processing Systems (NeurIPS), Sydney, Australia
Preliminary version appeared at ICML 2026 Workshop: Agents in the Wild (AIWILD)
Paper
Workshop Paper
RA-L'26
DiffusionPack: Offline Bin Packing with Custom Human Preferences
Preliminary version appeared at NeurIPS 2025 Workshop: Bridging Language, Agent, and World Models for Robotics
TMLR'26
V-OCBF: Learning Safety Filters from Offline Data via Value-Guided Offline Control Barrier Functions
* Equal contribution
Preliminary version appeared at AAAI 2026 Workshop on Deployable AI (DAI) (Oral)
RA-M'26
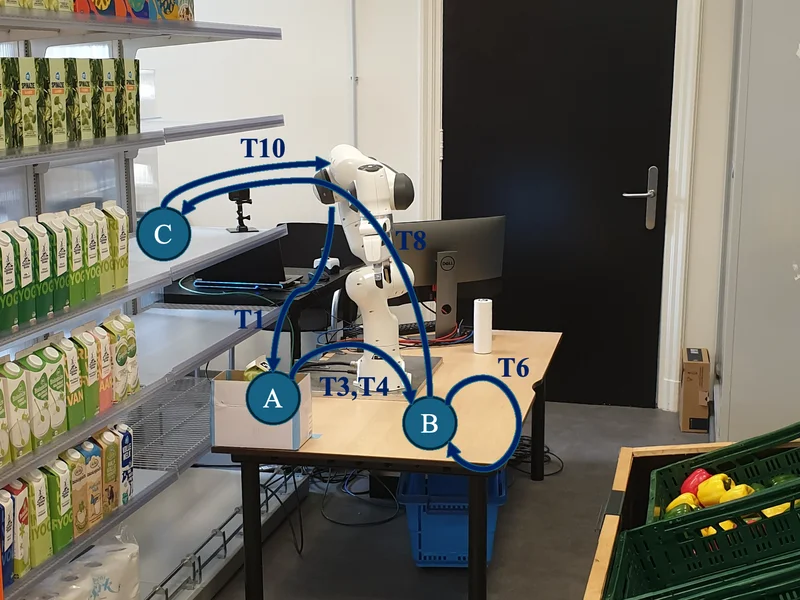
Sequentially Teaching Sequential Tasks (ST)2: Teaching Robots Long-Horizon Manipulation Skills
IROS'26
Beyond Visual Grasping: Benchmarking Complex Grasping from Detection to Execution
ECCV'26
Gripper-aware Vision Language Action Models
European Conference on Computer Vision (ECCV), Malmö, Sweden
RLC'26
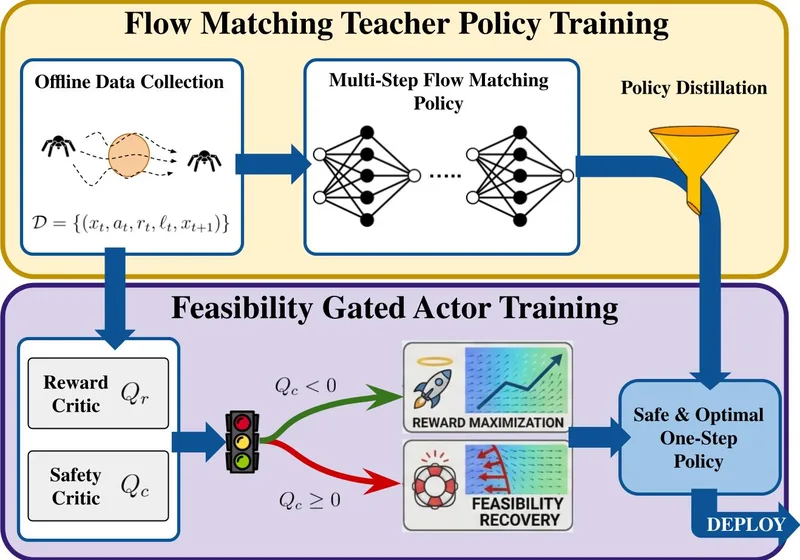
Safe Flow Q-Learning: Offline Safe Reinforcement Learning with Reachability-Based Flow Policies
* Equal contribution
Reinforcement Learning Conference (RLC), Montréal, Canada
Preliminary version appeared at ICML 2026 Workshop: Agents in the Wild (AIWILD)
CVPR'26
AffordMatcher: Affordance Learning in 3D Scenes from Visual Signifiers
ICRA'26
SafeDMPs: Integrating Formal Safety with DMPs for Adaptive HRI
IEEE International Conference on Robotics and Automation (ICRA), Vienna, Austria
Preliminary version appeared at CoRL 2025 2nd Workshop: Safe and Robust Robot Learning for Operation in the Real World
ICRA'26
Beyond the Teacher: Leveraging Mixed-Skill Demonstrations for Robust Imitation Learning
* Equal contribution
IEEE International Conference on Robotics and Automation (ICRA), Vienna, Austria
Preliminary version appeared at CoRL 2025 Workshop: Making Sense of Data in Robotics: Composition, Quality, and Data-centric Approaches
ICRA'26
Safe and Optimal Variable Impedance Control via Certified Reinforcement Learning
IEEE International Conference on Robotics and Automation (ICRA), Vienna, Austria
Preview coming soon
CoRLW'26
Corrections Are Evidence, Not Targets: Operator-Aware Inversion for Adapting Frozen Generative Robot Policies
Paper
Preview coming soon
RSSW'26
Where Reasoning Does Not Matter: Isolating Chain-of-Thought in a Modular, Agentic VLM Manipulation Pipeline
Preview coming soon
ICRAW'26
Latent Dynamics Modulation Guidance for Semantic Obstacle Avoidance in Diffusion Policies
ICRA 2026 Workshop: Semantics for Reliable Robot Autonomy, Vienna, Austria
Preview coming soon
ICRAW'26
The Topological Cage: A Search-Less Geometric Handshake for Medial Axis Injection
ICRA 2026 Workshop: Geometry in the Age of Data-Driven Robotics, Vienna, Austria
Preview coming soon
CVPRW'26
GenieMotion: Learning Object-Centric 4D Motion Representations from a Single Image via Generative Demonstrations
CVPR 2026 Workshop: 4D Vision, Denver, USA
Paper
Preview coming soon
ICRAW'26
State-Corrected Predictive Preference Learning for Multimodal Robot Navigation on Uneven Terrain
ICRA 2026 Workshop: Long-term Deployments in the Wild (LoWi), Vienna, Austria
2025
RA-L'25
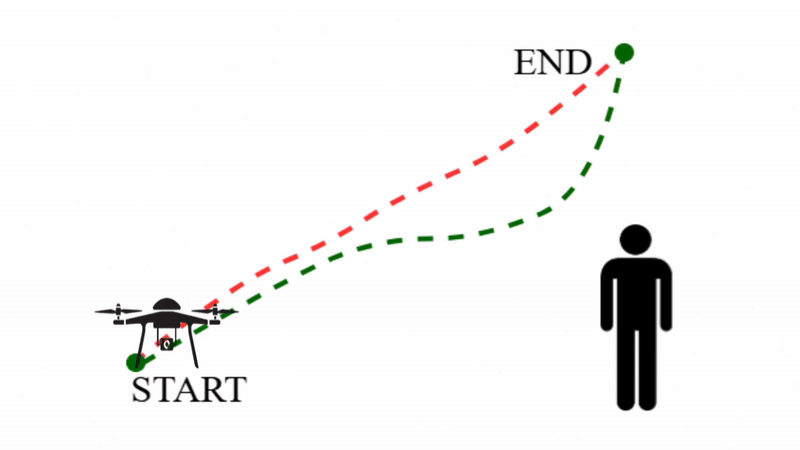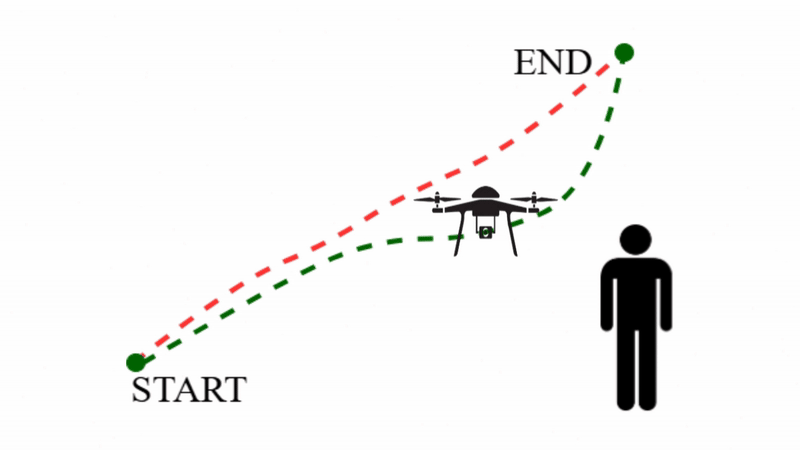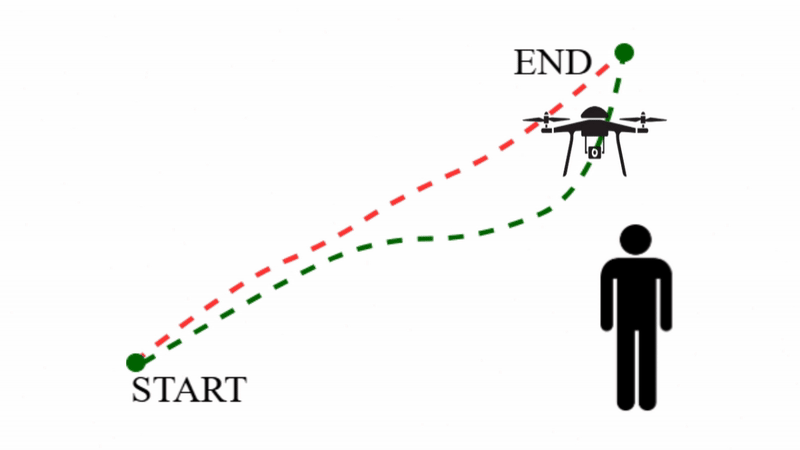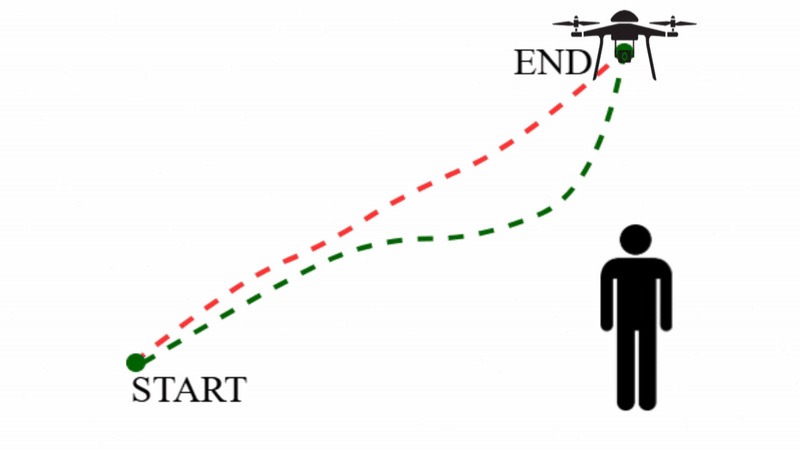
OVITA: Open-Vocabulary Interpretable Trajectory Adaptations
Preliminary version appeared at CoRL 2024 Workshop on Language and Robot Learning (LangRob)
T-RO'25
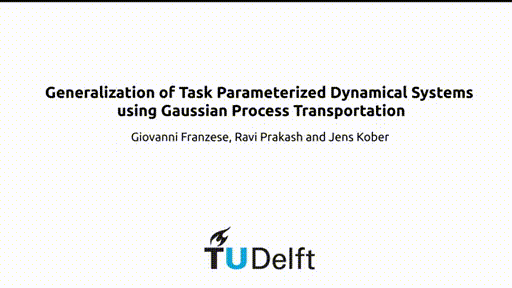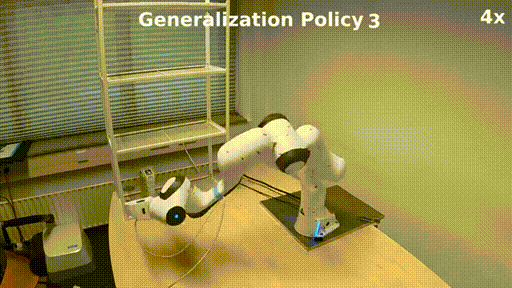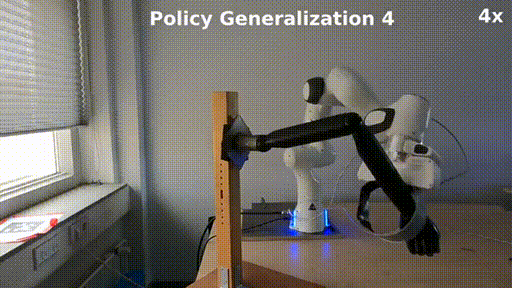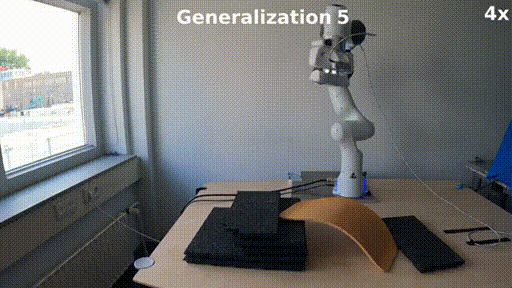
Generalizable motion policies through keypoint parameterization and transportation maps

ICRA'25
Impedance Primitive-Augmented Hierarchical Reinforcement Learning for Sequential Tasks
IROSW'25
RISE: Robust Imitation through Stochastic Encodings
CoRLW'25
PACER: Progress-Aligned Curation for Error-Resilient Imitation Learning
2024

T-CST'24
Adaptive Critic Optimal Control of an Uncertain Robot Manipulator With Applications

HRI'24
3rd Workshop on Human-Interactive Robot Learning (HIRL)